Quadruped Controller
An open-source quadruped robot controller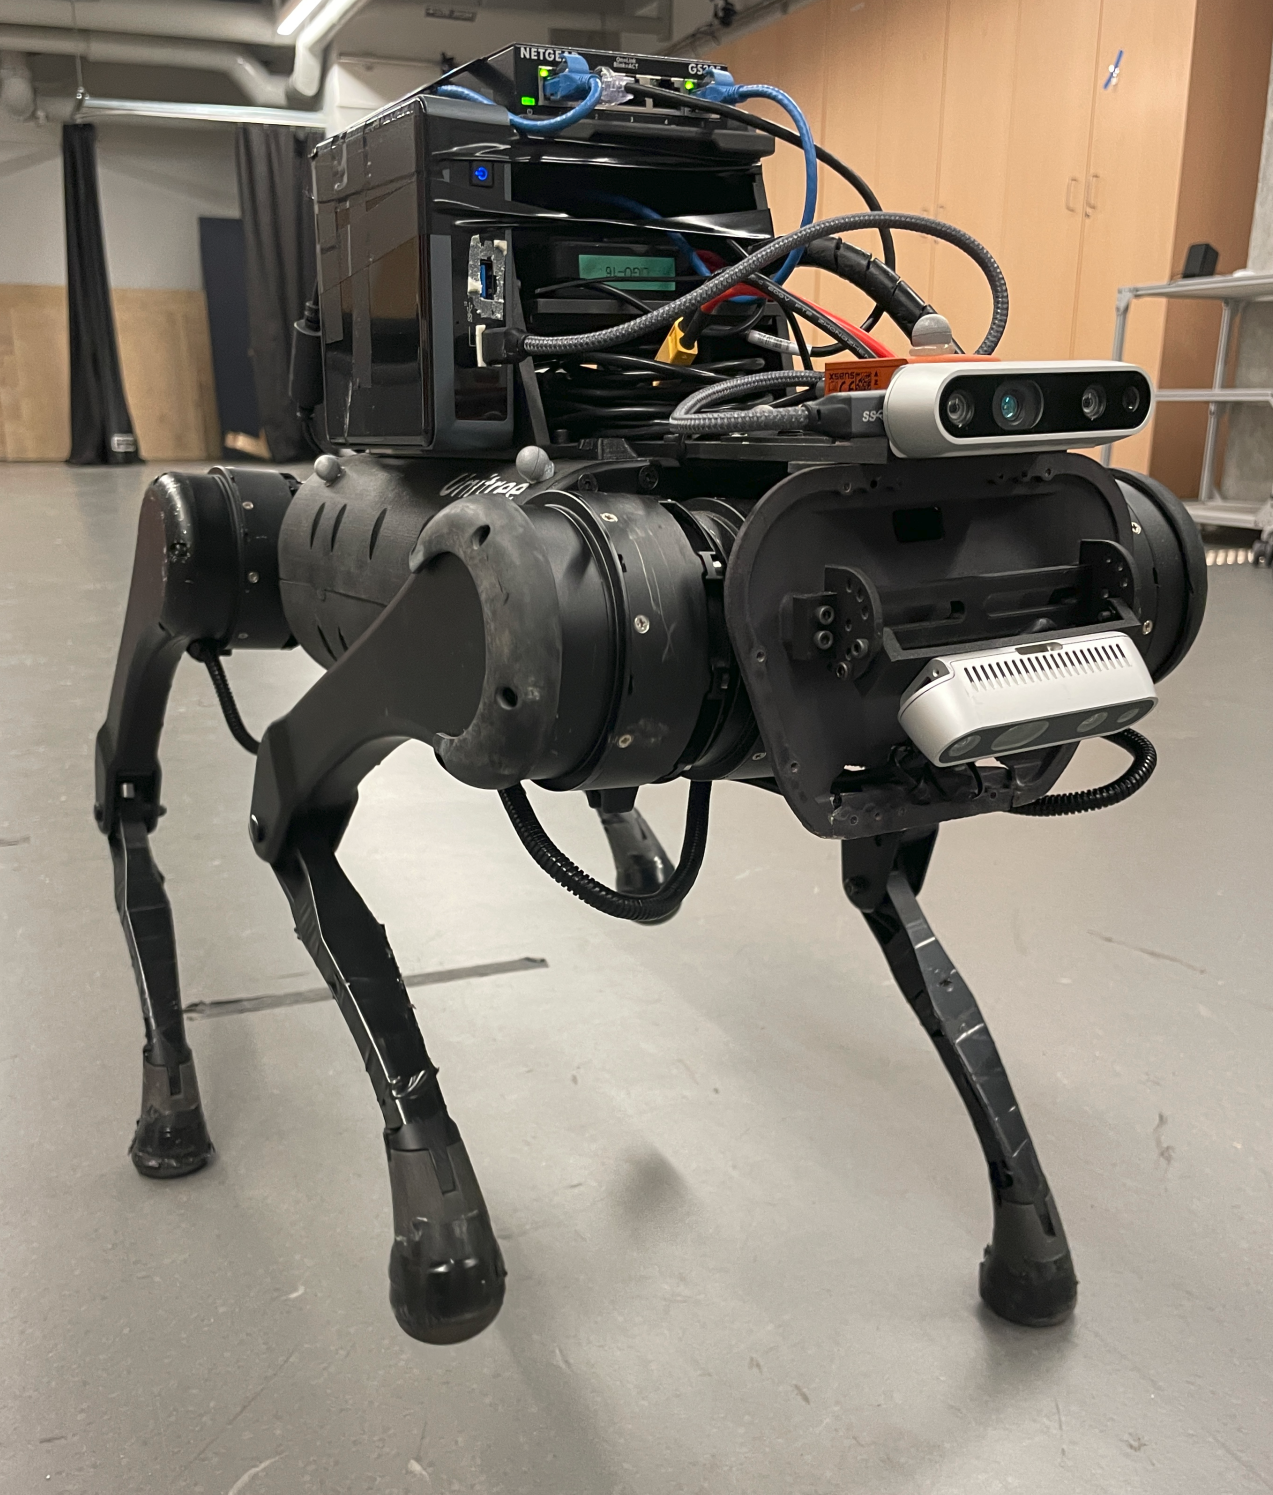
An open-source quadruped robot controller
A dynamic brachiation robot I made for the CMU 24-775 course project 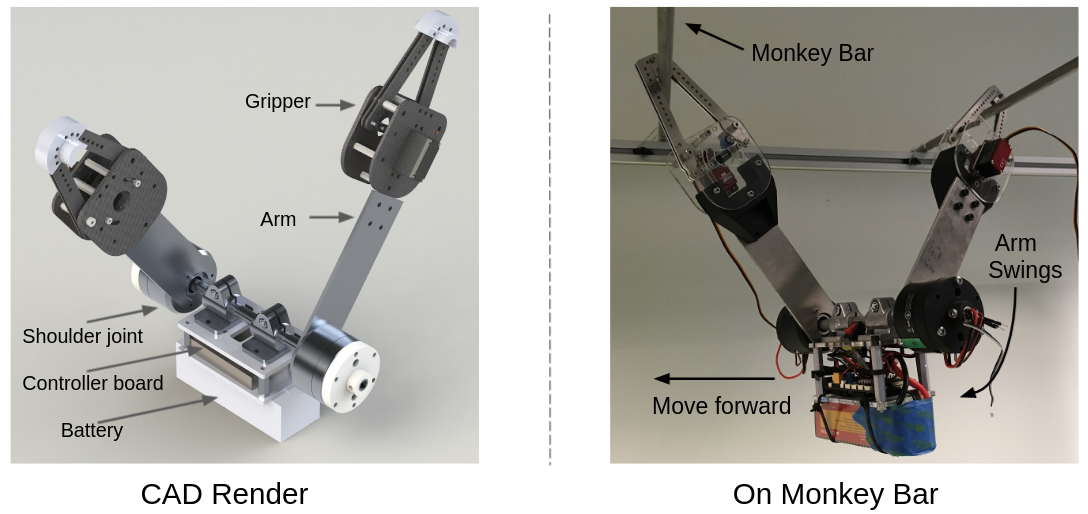
Published in 2015 IEEE International Conference on Robotics and Automation (ICRA), 2015
A vision-based landing controller.
Recommended citation: Shuo Yang, Jiahang Ying, Yang Lu, and Zexiang Li. "Precise quadrotor autonomous landing with SRUKF vision perception." In 2015 IEEE International Conference on Robotics and Automation (ICRA), pp. 2196-2201. IEEE, 2015. https://ieeexplore.ieee.org/abstract/document/7139489
Published in 2015 IEEE International Conference on Robotics and Automation (ICRA), 2015
A quadrotor controller developed by me and my DJI colleagues.
Recommended citation: Yu, Yun, Shuo Yang, Mingxi Wang, Cheng Li, and Zexiang Li. "High performance full attitude control of a quadrotor on SO (3)." In 2015 IEEE International Conference on Robotics and Automation (ICRA), pp. 1698-1703. IEEE, 2015. https://ieeexplore.ieee.org/abstract/document/7139416
Published in 2021 IEEE International Conference on Robotics and Automation (ICRA), 2021
A theoretical attempt to unify trajectory generation and state estimation.
Recommended citation: Yang, Shuo, Gerry Chen, Yetong Zhang, Howie Choset, and Frank Dellaert. "Equality constrained linear optimal control with factor graphs." In 2021 IEEE International Conference on Robotics and Automation (ICRA), pp. 9717-9723. IEEE, 2021. https://ieeexplore.ieee.org/abstract/document/9562000
Published in IEEE Robotics and Automation Letters & 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022
Online calibration of kinematic parameters for legged robots.
Recommended citation: Yang, Shuo and Choset, Howie and Manchester, Zachary. "Online Kinematic Calibration for Legged Robots," in IEEE Robotics and Automation Letters, 2022, doi: 10.1109/LRA.2022.3186501 https://ieeexplore.ieee.org/document/9807408
Published in 2023 IEEE International Conference on Robotics and Automation (ICRA), 2023
An MPC controller for a novel quadruped robot.
Recommended citation: Chi-yen Lee, Shuo Yang, Benjamin Bokser, and Zachary Manchester. "Enhanced Balance for Legged Robots Using Reaction Wheels." In 2023 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2023.
Published in 2023 IEEE International Conference on Robotics and Automation (ICRA), 2023
Visual-inertial-leg odometry for agile locomotion.
Recommended citation: Shuo Yang, Zixin Zhang, Zhengyu Fu, and Zachary Manchester. "Cerberus: Low-Drift Visual-Inertial-Leg Odometry for Agile Locomotion." In 2023 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2023.
Published in 2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
Multi-IMU proprioceptive odometry for legged robots.
Recommended citation: Yang S, Zhang Z, Bokser B, et al. Multi-IMU Proprioceptive Odometry for Legged Robots[C]//2023 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). IEEE, 2023: 774-779.
Published in IEEE Transactions on Robotics, 2024
Contact-implicit model predictive control.
Recommended citation: Le Cleach, Simon and Howell, Taylor A and Yang, Shuo and Lee, Chi-Yen and Zhang, John and Bishop, Arun and Schwager, Mac and Manchester, Zachary. "Fast Contact-implicit Model Predictive Control." IEEE Transactions on Robotics.
Published in arXiv preprint arXiv:2603.10448, 2026
A video-action Diffusion Transformer framework for generalizable robot control.
Recommended citation: Ma, Teli and Zheng, Jia and Wang, Zifan and Jiang, Chunli and Cui, Andy and Liang, Junwei and Yang, Shuo. "DiT4DiT: Jointly Modeling Video Dynamics and Actions for Generalizable Robot Control." arXiv preprint arXiv:2603.10448, 2026. https://arxiv.org/abs/2603.10448
Undergraduate course, CMU, Mechanical Engineering, 2020
This first course on the modeling and analysis of dynamic systems concentrates on the motion of particles, systems of particles, and rigid bodies under the action of forces and moments. Topics include the kinematics of motion in rectangular, polar, and intrinsic coordinates; relative motion analysis with multiple reference frames; and planar kinetics through the second law, work-energy method, and impulse-momentum method. Time- and frequency-domain solutions to first- and second-order equations of motion are discussed.
Undergraduate course, CMU, Mechanical Engineering, 2021
This second course on the modeling and analysis of dynamic systems emphasizes the common features exhibited by physical systems that include mechanical, hydraulic, pneumatic, thermal, electrical, and electromechanical elements. State equations and the concepts of equilibrium, linearization, and stability are discussed. Time- and frequency-domain solutions are developed.