Quadruped Controller
I needed to build a quadruped platform with basic control and estimation capabilities to support my own research. After reading the papers “MIT Cheetah 3: Design and Control of a Robust, Dynamic Quadruped Robot” and “Dynamic Locomotion in the MIT Cheetah 3 Through Convex Model-Predictive Control,” I implemented the controller and state estimator described in them. The code is available on GitHub.
Based on this work, I recently published a paper in IEEE Robotics and Automation Letters.
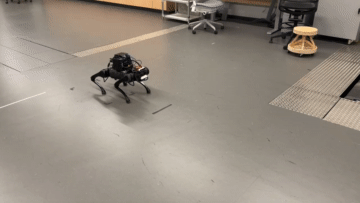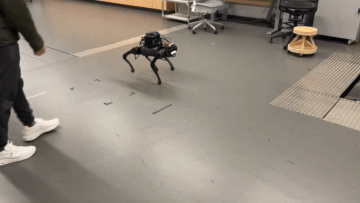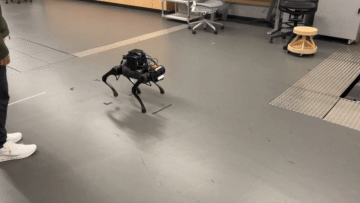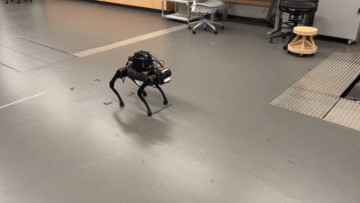
The videos below show the performance of this controller.